A new dimension to access content of this website
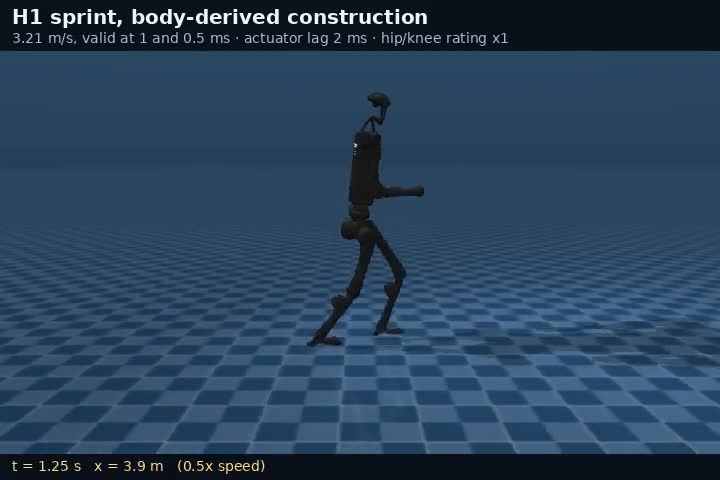
Deriving jumping, throwing, running, and carrying motions from robot geometry and motor limits in MuJoCo. Simulation studies across humanoid bodies without human demonstration data.